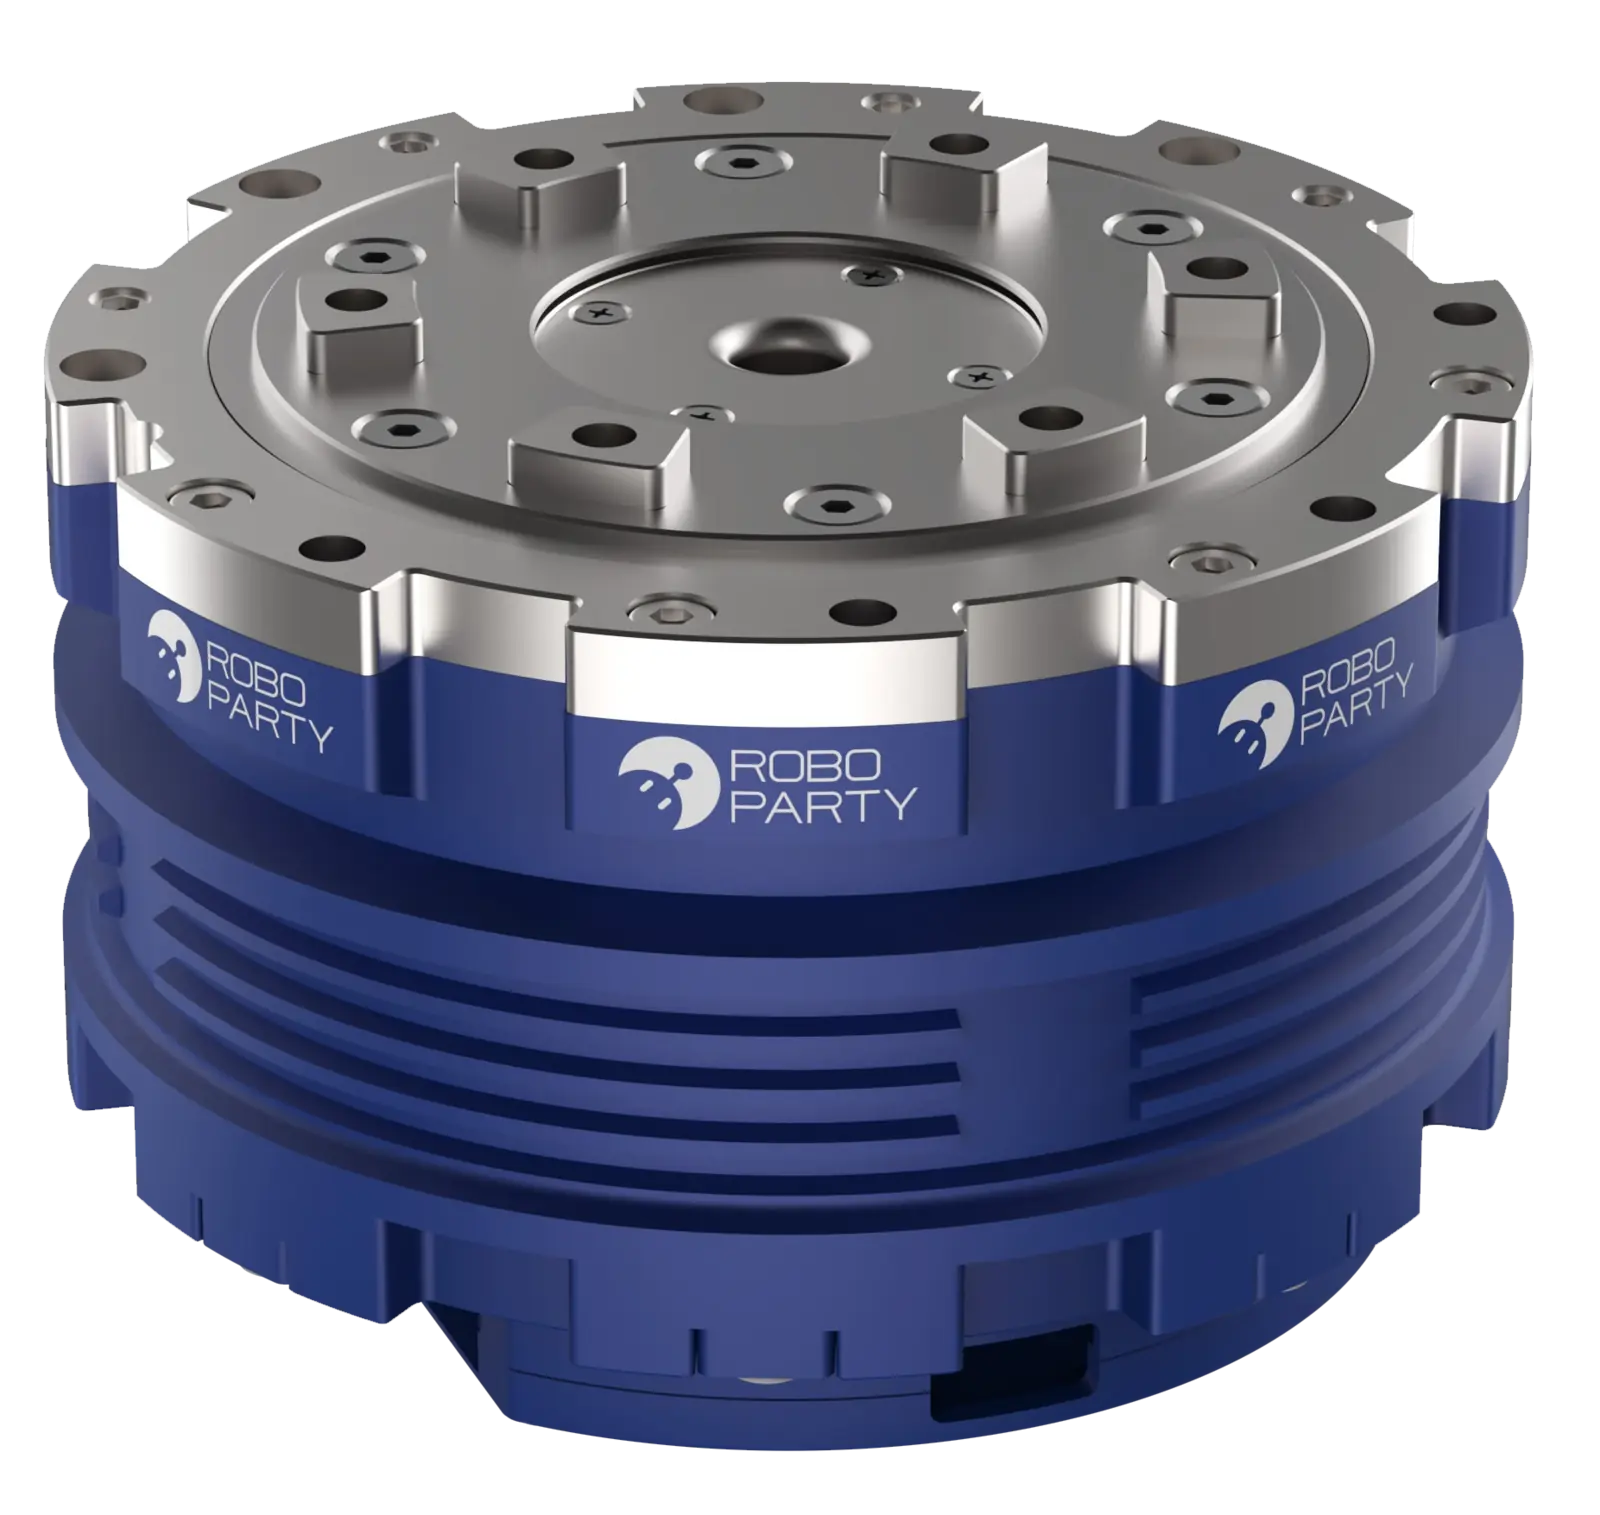
ROMOMO
High-torque joint actuators, the same modules inside ROBOTO 01.
Compact planetary joint modules with dual encoders, a hollow bore for through-wiring and open-source drawings and driver code. Three sizes, from 35 to 160 N·m peak torque.
 TORQUERO
High-torque joint actuators, the same modules inside ROBOTO 01.
Compact planetary joint modules with dual encoders, a hollow bore for through-wiring and open-source drawings and driver code. Three sizes, from 35 to 160 N·m peak torque.
| Peak torque | 35 / 42 / 160 N·m |
|---|---|
| Rated torque | 10 / 14 / 44 N·m |
| Gear ratio | 19.5:1 / 20:1 / 22:1 |
| Weight | 533 / 779 / 1197 g |
| Voltage | 48 V |
| Encoders | Dual, 17-bit motor / 19-bit output |
| Interfaces | CAN FD / EtherCAT |
Specifications are provided by RoboParty and may change. Ask us for current availability, versions and pricing.