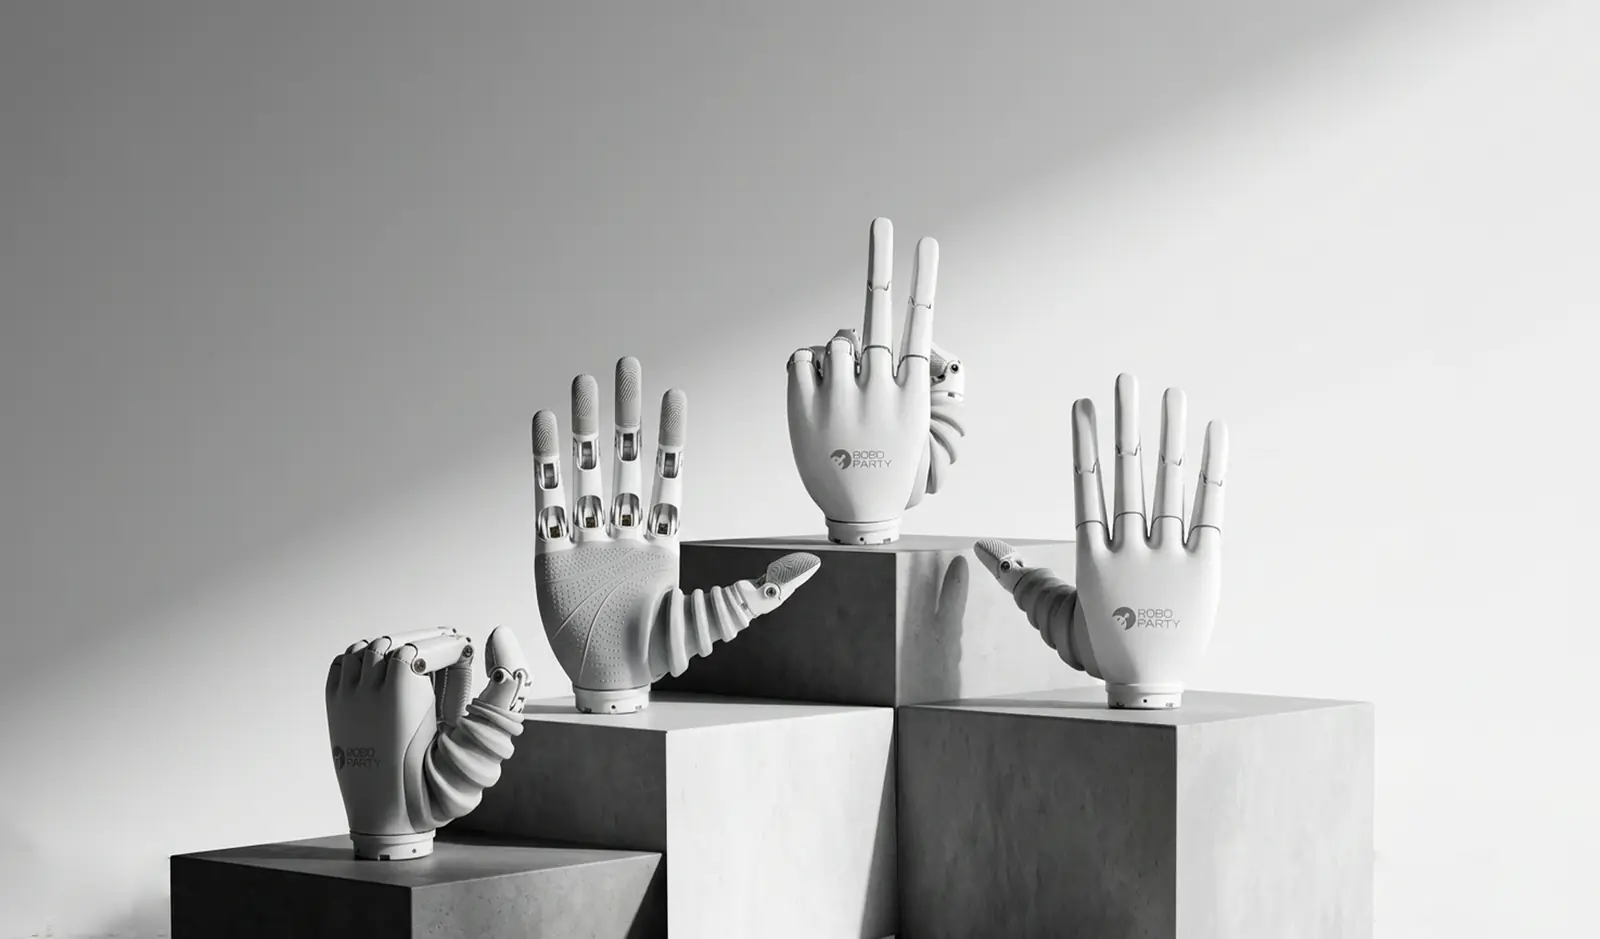
RP Hand
Light, compact dexterous hand for humanoid robots.
An 11-DOF dexterous hand with 6 active joints, worm-gear drive and optional palm and fingertip tactile sensing. Ships with an open-source SDK, host software and URDF/MJCF/STEP models.
 TORQUERO
Light, compact dexterous hand for humanoid robots.
An 11-DOF dexterous hand with 6 active joints, worm-gear drive and optional palm and fingertip tactile sensing. Ships with an open-source SDK, host software and URDF/MJCF/STEP models.
| Weight | 379 g |
|---|---|
| Size | 148 × 74 × 26 mm |
| Degrees of freedom | 11 (6 active) |
| Open/close time | ≤ 0.7 s |
| Tactile (optional) | Palm 0–25 N, fingertips 0–20 N + shear |
| Interfaces | EtherCAT + CAN FD or RS485 |
| Supply voltage | 12–48 V |
| Software | ROS 2, C++, Python; Windows & Linux |
Specifications are provided by RoboParty and may change. Ask us for current availability, versions and pricing.