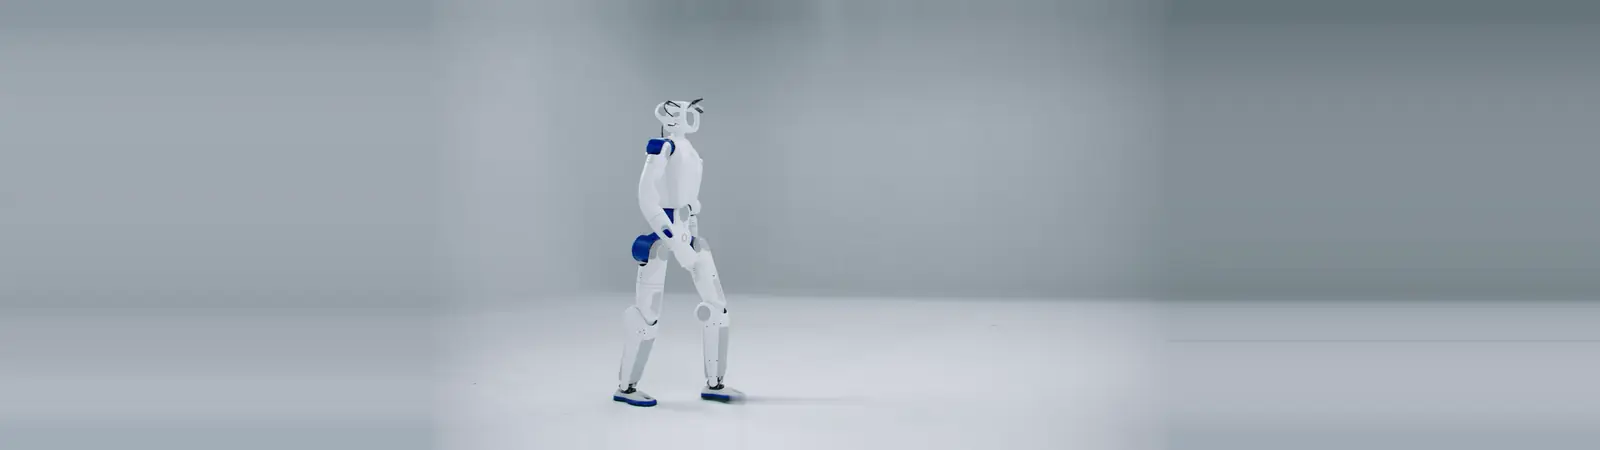
ROBOTO 01
Modular, full-stack open-source humanoid for research and development.
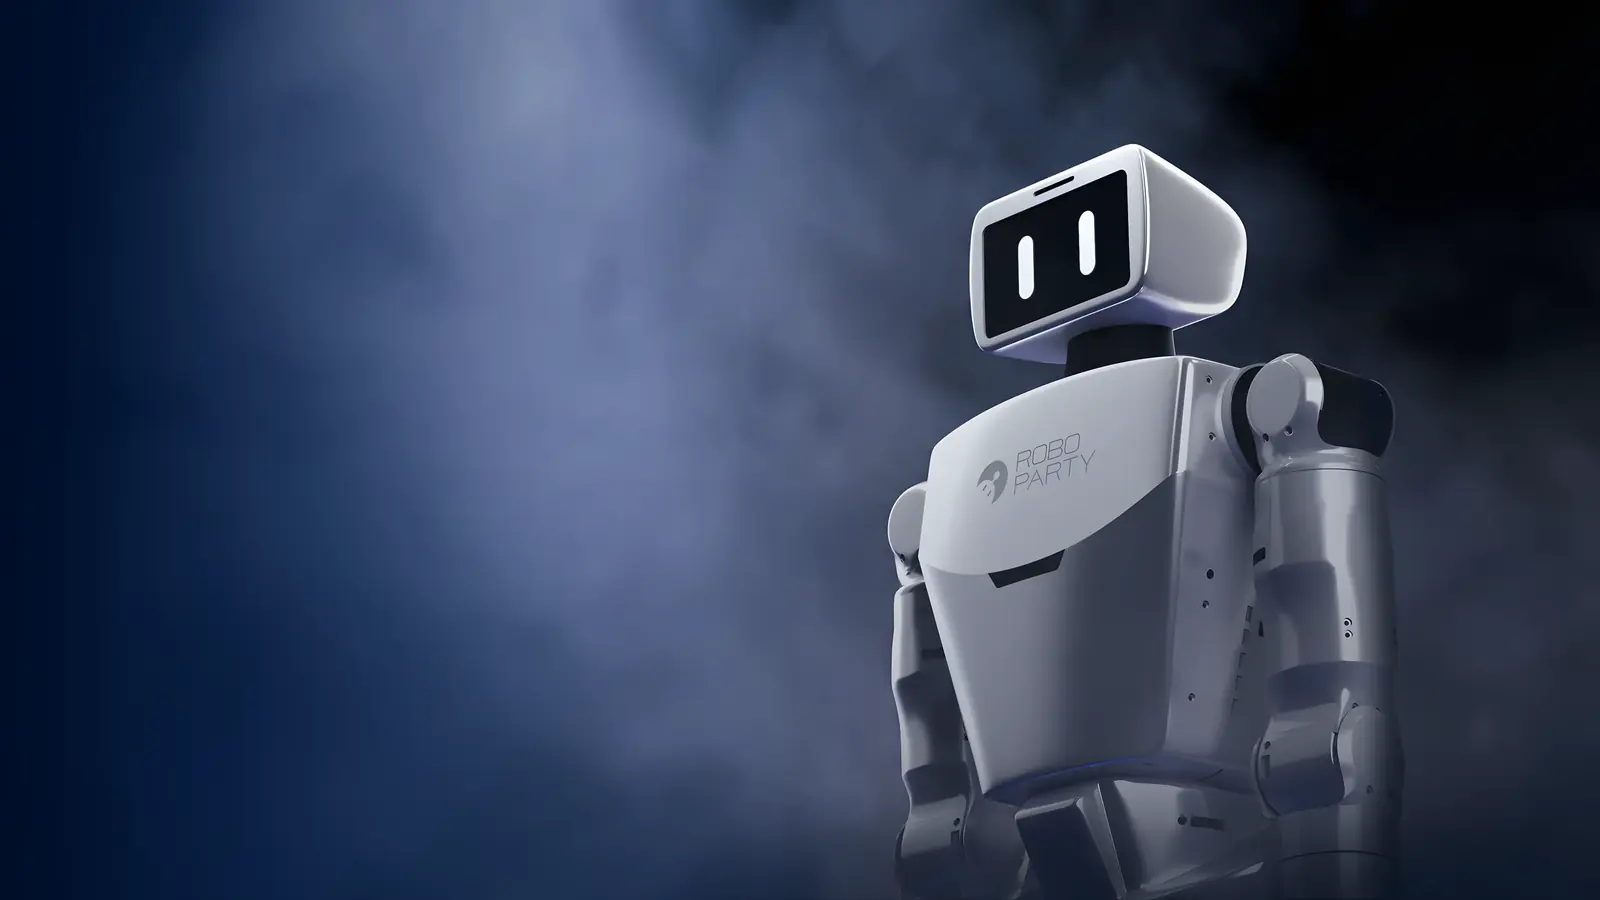
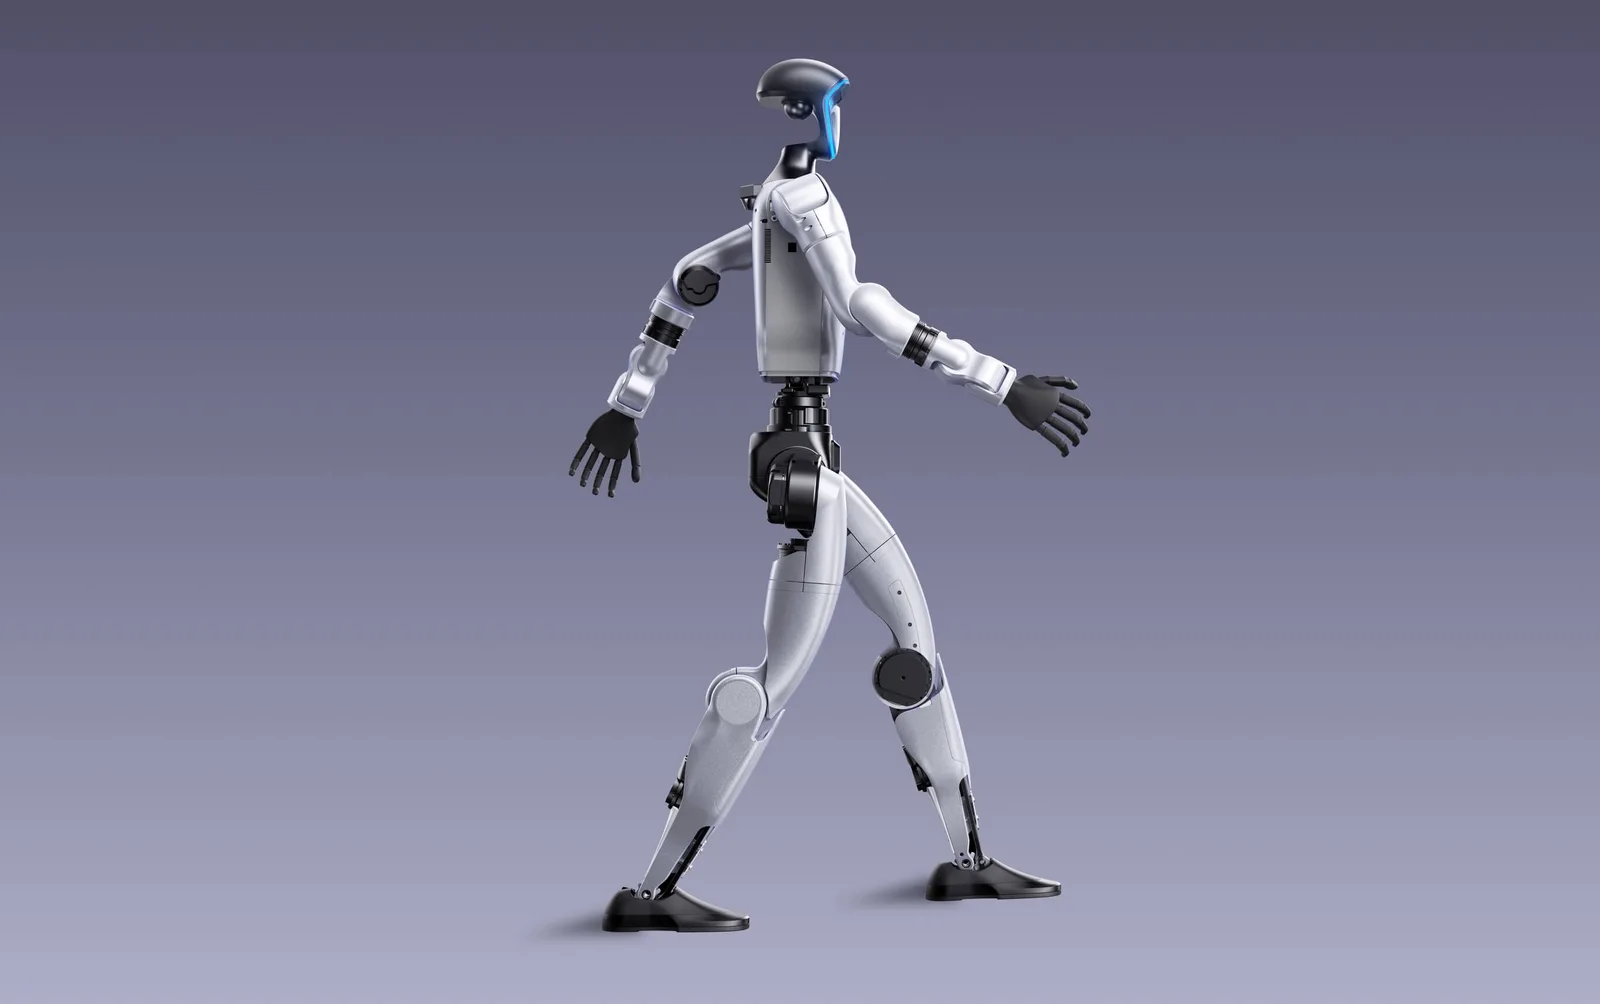
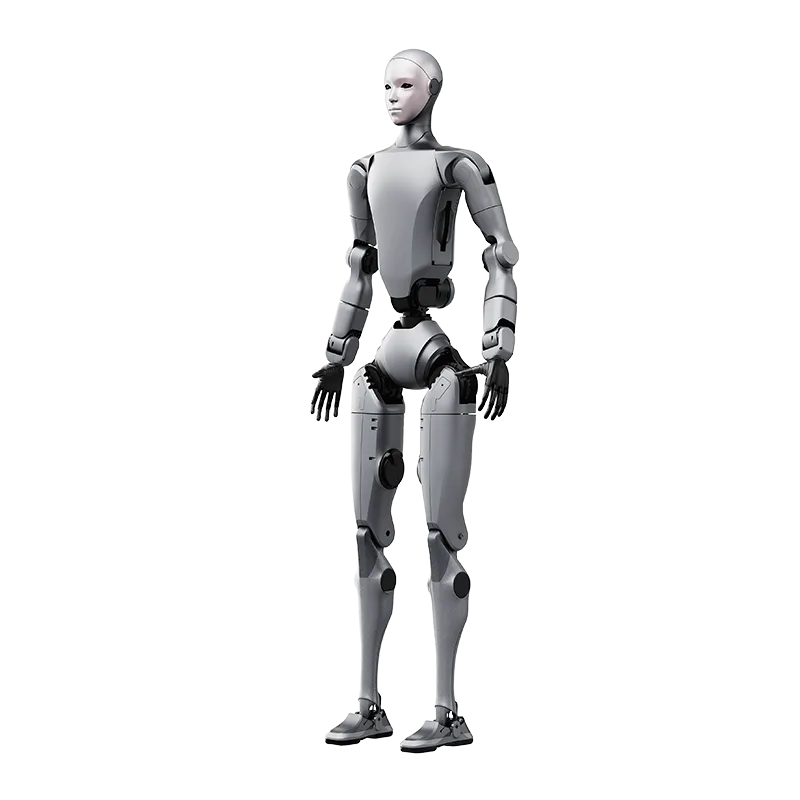
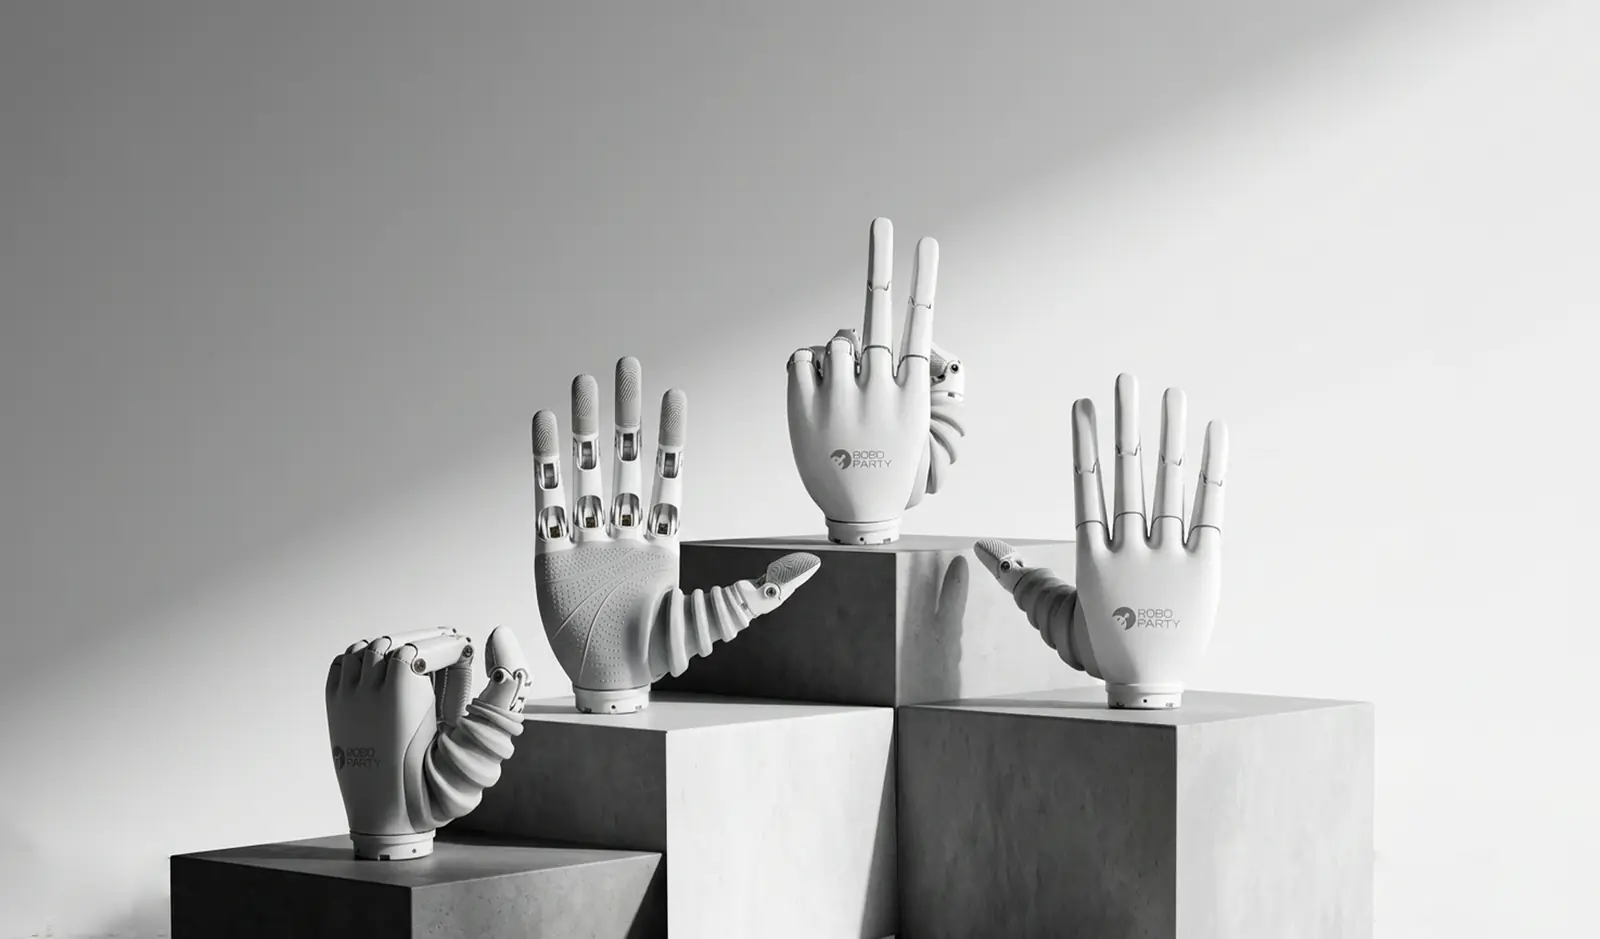
A 1.35 m humanoid built for labs and independent developers. Swappable heads (motion control, interaction, perception, data collection) and interchangeable hands, with hardware, firmware, gait algorithms, ROS 2 middleware, SDK and simulation all open source.
- Height
- 1.35 m
- Weight
- ~39 kg (Pro ~41 kg)
- Degrees of freedom
- 24 (Pro 30)
Full specifications
| Height | 1.35 m |
|---|---|
| Weight | ~39 kg (Pro ~41 kg) |
| Degrees of freedom | 24 (Pro 30) |
| Peak joint torque | 160 N·m |
| Top speed | up to 4 m/s |
| Arm payload | 5 kg |
| Battery | 10 Ah hot-swap, ~3 h runtime, 1.5 h charge |
| Compute | RK3588 (Pro adds A733; Orin NX module optional) |
| Connectivity | Wi-Fi 6, Bluetooth 5.2, 4G |
| Software | ROS 2, SDK, simulation & training code |