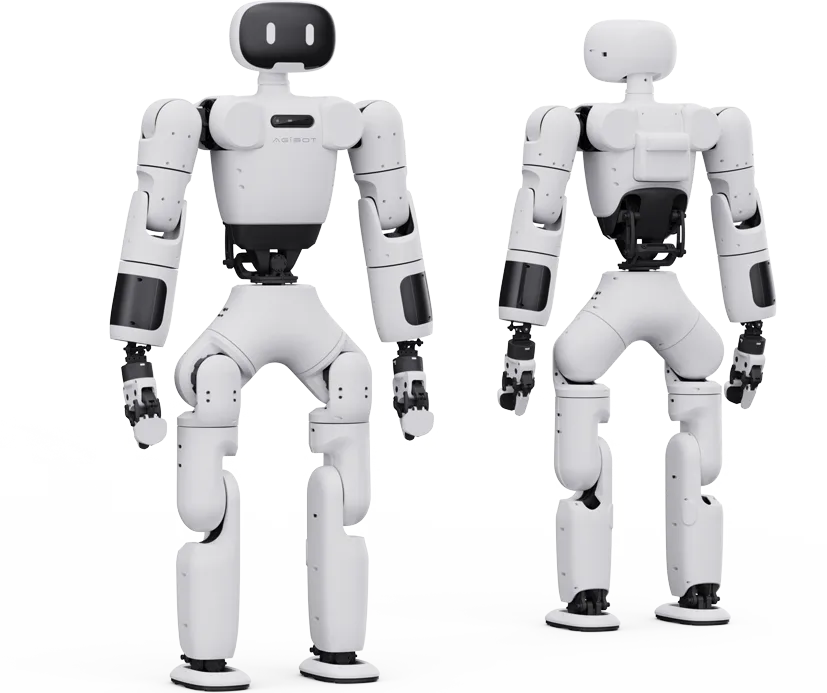
AgiBot X1
Full-stack open-source humanoid with 34 degrees of freedom.
A modular 1.3 m humanoid whose design, AimRT software framework and documentation are open, backed by the AgiBot World dataset. Built around AgiBot's PowerFlow joint modules.
 TORQUERO
Full-stack open-source humanoid with 34 degrees of freedom.
A modular 1.3 m humanoid whose design, AimRT software framework and documentation are open, backed by the AgiBot World dataset. Built around AgiBot's PowerFlow joint modules.
| Height | 1.30 m |
|---|---|
| Weight | 33 kg |
| Degrees of freedom | 34 |
| Peak joint torque | 200 N·m |
| Walking speed | 1 m/s |
| Runtime | ~2 h |
| Interfaces | EtherCAT to FDCAN control units |
| Development | Open source, Linux SDK, AimRT framework |
Specifications are provided by AgiBot and may change. Ask us for current availability, versions and pricing.