
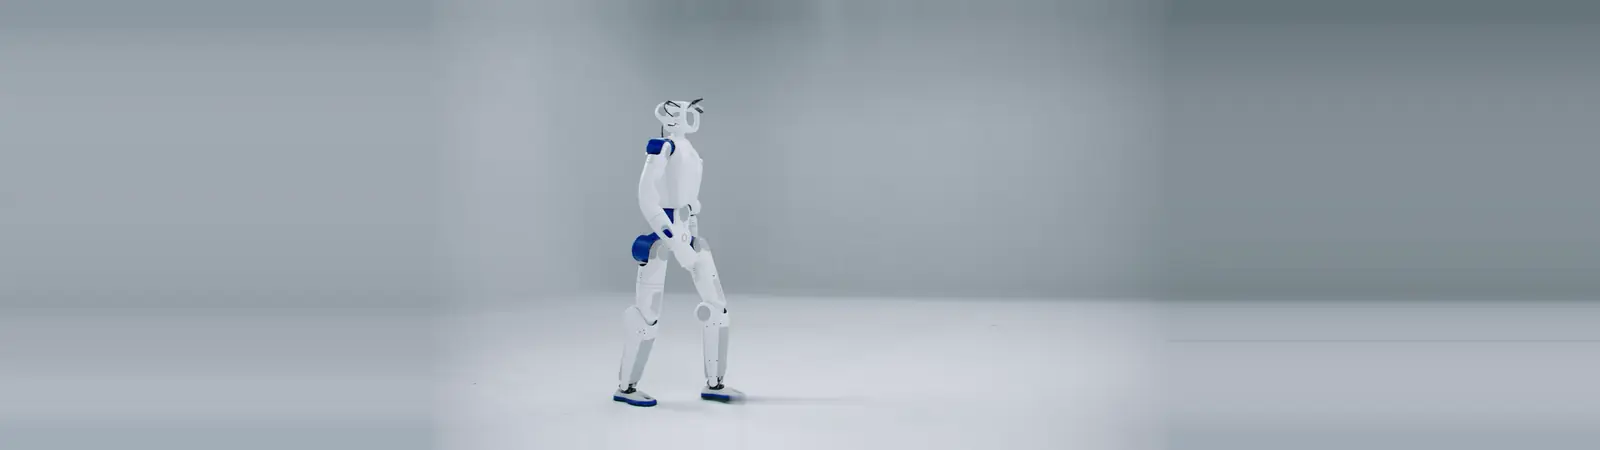
ROBOTO 01
Modular, full-stack open-source humanoid for research and development.
A 1.35 m humanoid built for labs and independent developers. Swappable heads (motion control, interaction, perception, data collection) and interchangeable hands, with hardware, firmware, gait algorithms, ROS 2 middleware, SDK and simulation all open source.