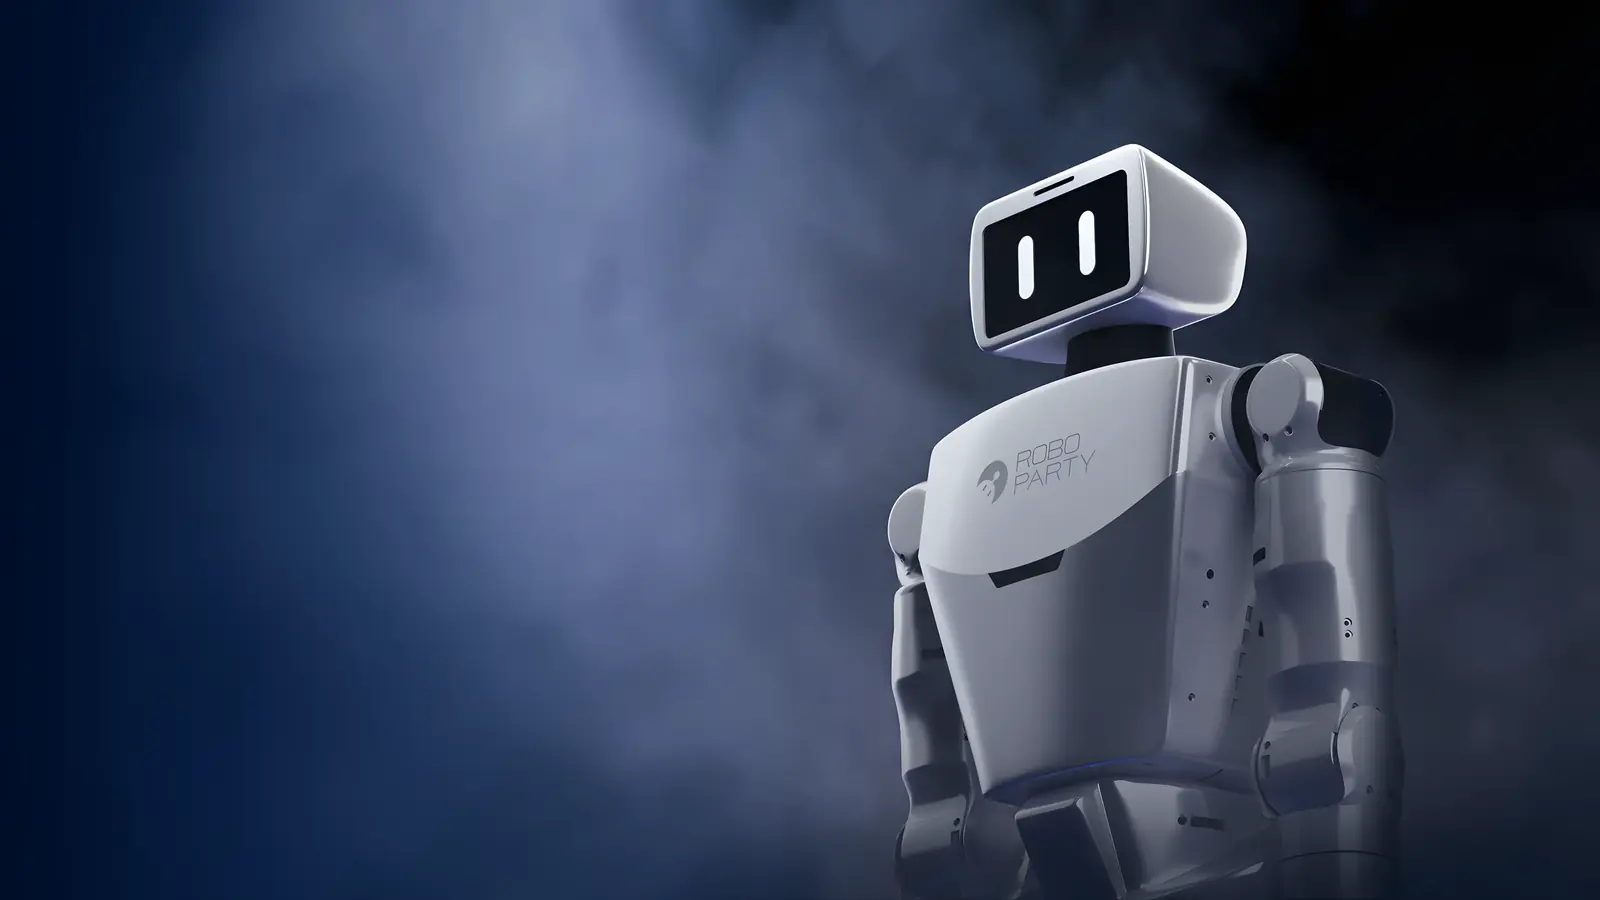
ROBOTO Origin by RoboParty

Humanoid robots · RoboParty

ROBOTO Origin

Hand-built, open-source humanoid. Learn humanoids from zero.

A build-it-yourself humanoid with CNC-machined parts, parallel ankle joints and a separate skeleton and shell. Mechanical design, electronics, control algorithms and simulation files are all open, which makes it a strong teaching platform.

Made for

Universities & labsAdvanced studentsMakers

Popular for

ROBOTO Origin specifications

Height1.25 m
Weight34 kg
Degrees of freedom23
Peak joint torque120 N·m leg / 27 N·m arm
Top speed3 m/s
Battery48 V 15 Ah, 2 h+ runtime
Sensors (optional)Intel D435i depth camera, 3D LiDAR
ConnectivityWi-Fi 6, Bluetooth 5.2, OTA updates
SoftwareROS 2, low-level control SDK

Specifications are provided by RoboParty and may change. Ask us for current availability, versions and pricing.